
🟧 micro:bit Examples: Vision Sensor ESP32CAM
Back to Vision Sensor ESP32CAM × micro:bit | Product page | Reference
This page is for people who have never written code. The 6 examples start with "show a value on the LEDs" and build up to "drive a car". Everything is written for the MakeCode web editor with the MBC extension pxt-mbc-sensors v2: switch to JavaScript, paste an example and it runs; switch back to Blocks to see which blocks it becomes.
Important
- Extension pxt-mbc-sensors v2 has not been verified on hardware yet. Every example on this page compiles with the MakeCode CLI (once for V1, once for V2); value directions, ready times and power are still to be confirmed on a real board, see "to be tested" in the hardware checklist below.
- Use the Universal I2C edition of the product. The SPIKE and EV3 editions have different firmware and cannot be read by a micro:bit.
Tip
Examples 1–5 are for the school edition (hue / blob / motion), example 6 for the WRO edition (HUE12, 12 colour spots). Which colour to watch or which blob to track can only be set with the buttons on the camera (not from code): examples 1 and 2 need "Setting 1: COLOR", examples 3–5 need "Setting 2: TRACK"; steps on the product page.
Software
| Editor | micro:bit V1 | micro:bit V2 | How |
|---|---|---|---|
| MakeCode web editor (makecode.microbit.org, Blocks / JavaScript) | ✔ (less memory, but every example here fits) | ✔ | New Project → gear → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript (top) → paste the example → Download the .hex and drag it onto the MICROBIT drive |
| MakeCode offline app (Windows / Mac) | ✔ | ✔ | Same; adding the extension the first time needs internet |
| Python Editor (MicroPython) | — | — | no MBC module yet |
- Sound: V2 has a built-in speaker; a V1 needs a buzzer or headphones on P0.
- Servos / motors: the examples use
pins.servoWritePin: one 9 g servo (SG90) on P1; for driving, two continuous-rotation servos (e.g. FS90R), left wheel P1, right wheel P2. Always power servos from an external 4.8–6 V battery pack whose − is joined to the micro:bit GND (common ground); never drive servos from the micro:bit 3V pin. - Block names: with the editor language set to English the blocks read as in the tables below; the tables also give the JavaScript call.
Before you start: hardware checklist (to be tested)
The micro:bit is a 3.3 V board. Each check must pass before an MBC product is connected; "to be tested" marks items extension v2 has not yet confirmed on real hardware.
| Check | This product | Status |
|---|---|---|
| Voltage | MBC products use 3.3 V I2C levels: connect straight to P19 / P20, no level shifter | ✔ |
| Power | the ESP32 camera peaks above 300 mA: external 5 V is required (power bank or a 2 A adapter), never the micro:bit 3V pin | to be tested |
| I2C pull-ups | the micro:bit already has 4.7 kΩ; if the product also has pull-ups, check the low level stays ≤ 0.3×VDD | to be tested |
| Clock stretching | the ESP32 cannot stretch the clock: the extension waits 2 ms after writing the id before reading, nothing to do yourself | to be tested |
| Address clash | factory address 0x4C (school and WRO editions alike); the I2C pins are IO3 (SDA) / IO1 (SCL), so the camera USB serial monitor is unavailable while I2C is connected | — |
| Ready time | the camera is ready (F3 b0) about 3 s after power-on; power the camera first, then the micro:bit. The I2C interface was decided on 2026-10-21: hardware confirmed, bench test pending | to be tested |
If you read nothing: check the wiring (SDA = P20, SCL = P19) → the external power → whether the "device at … is ready" block (Device group, advanced) returns true.
Wiring (the same for every example)
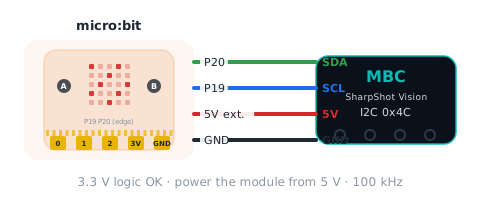
| Sensor | micro:bit |
|---|---|
| SDA | P20 |
| SCL | P19 |
| VCC | external 5 V (required) |
| GND | GND (the servo battery − goes here too) |
The values used on this page
Hue 0..100: red 0 (100 is red too), yellow ≈ 17, green ≈ 33, cyan ≈ 50, blue ≈ 67, magenta ≈ 83; −1 = black, white or grey. Blob X 0..100 (left 0, right 100), Y 0..75 (bottom 0, top 75), area = width × height (0..7500, 0 = not found).
| Block | JavaScript | Range | Meaning | Used in |
|---|---|---|---|---|
| camera colour hue / saturation / brightness | mbc.camColor(MbcCamColor.Hue) |
−1~100 / 0~100 | the colour at the sampling point in the picture centre | 1, 2 |
| camera colour is black / white / grey | mbc.camIsGrey() |
true / false | hue = −1 | 1, 2 |
| camera blob is found | mbc.camFound() |
true / false | a blob of the target colour is in the picture | 3, 4, 5 |
| camera blob X / Y / width / height / area | mbc.camBlob(MbcCamBlob.X) |
0~100 / 0~75 / 0~7500 | blob position and size | 3, 4, 5 |
| on camera blob found / lost | mbc.onCamBlob(MbcCamEvent.Found, ...) |
事件 | runs once when the blob appears or disappears | 5 |
| camera motion | mbc.camMotion() |
0~100 | how much the whole picture changed since the last frame | 5 |
| camera spot n colour code (WRO) | mbc.camSpotColor(1) |
0~255 | 0..239 colour, 240..245 white, 246..250 black, 255 = spot off | 6 |
| camera spot n is colour / white / black / off (WRO) | mbc.camSpotIs(1, MbcCamSpotKind.Colour) |
true / false | the colour code sorted into four kinds | 6 |
| camera spot n vividness (WRO) | mbc.camSpotVivid(1) |
0~255 | saturation; black = 1, spot off = 0 | 6 |
| wait for device at … ready | mbc.waitReady(mbc.ADDR_CAM, 5000) |
true / false | waits up to 5 s, true once the camera is up (Advanced → Device) | 1, 6 |
Example 1: What colour is it
What this example does: An LED bar shows the hue at the centre of the picture: red almost empty (0), green a third, blue two thirds; black / white / grey shows a small square. Press A to show the hue number, B the saturation.
What you need
- micro:bit V1 or V2 + USB cable
- Vision Sensor ESP32CAM school edition (I2C wires on IO3 / IO1) + external 5 V
- red, green and blue bricks or paper
- the camera with "Setting 1: COLOR" done
Wiring: As in the wiring table above: camera IO3 (SDA) → P20, IO1 (SCL) → P19, 5V → external 5 V, GND → GND (the external supply − must also go to micro:bit GND).
Download: ex01_show_hue.ts (right-click, save) → MakeCode New Project → gear → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript (top) → select all, delete, paste the file → Download and drag the .hex onto the MICROBIT drive.
Code
// Vision sensor ESP32CAM (school edition) × micro:bit example 1: what colour is it (hue bar)
// What it does: the LED bar shows the hue at the centre of the picture (red 0 → yellow 17 → green 33 → blue 67 → red 100); black / white / grey shows a small square. Press A to show the hue number, B the saturation.
// Wiring: camera SDA (IO3) → P20, SCL (IO1) → P19, VCC → external 5 V (the ESP32 draws too much for the micro:bit 3V pin), GND → GND (common ground).
// Setup: do 'Setting 1: COLOR' on the camera first (see the product page). MakeCode new project → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript, paste this whole file → download to the micro:bit.
// You see: a tick at power-on (camera found); a red brick → bar almost empty (0); green → 1/3 lit; blue → 2/3 lit; white paper → a small square.

let busy = false

if (mbc.waitReady(mbc.ADDR_CAM, 5000)) {                  // the camera takes about 3 s to boot
    basic.showIcon(IconNames.Yes)
} else {
    basic.showIcon(IconNames.No)                          // no answer: check P19 / P20 and the external power; power the camera before the micro:bit
}

basic.forever(function () {
    if (busy) {
        basic.pause(100)
        return
    }
    if (mbc.camIsGrey()) {                                // hue −1: black, white or grey
        basic.showIcon(IconNames.SmallSquare, 0)
    } else {
        led.plotBarGraph(mbc.camColor(MbcCamColor.Hue), 100)   // 0..100
    }
    basic.pause(100)
})

input.onButtonPressed(Button.A, function () {
    busy = true
    basic.showNumber(mbc.camColor(MbcCamColor.Hue))
    busy = false
})
input.onButtonPressed(Button.B, function () {
    busy = true
    basic.showNumber(mbc.camColor(MbcCamColor.Saturation))   // 0..100, higher = more vivid
    busy = false
})
Step by step
mbc.waitReady(mbc.ADDR_CAM, 5000): the camera boots in about 3 s; tick once it answers.forever:mbc.camIsGrey()(hue −1) → small square.- Otherwise
led.plotBarGraph(mbc.camColor(Hue), 100): hue 0..100 as a bar. - A: show the hue; B: the saturation (0..100, higher = more vivid).
busypauses the bar meanwhile.
What you should see
- A tick about 3 s after power-on.
- Red brick: bar almost empty, A shows 0–5 or 95–100.
- Green: about a third; blue: about two thirds.
- White paper: small square, A shows −1.
FAQ
- Hue is always 0? → "Setting 1: COLOR" has not been done; 0 is easy to mistake for red. Set the sampling point on the camera.
- An X at power-on? → The camera has no power or is still booting: power it first, wait for the picture, then press reset on the micro:bit.
- The camera picture is upside down? → Turn V-Flip ON in the camera lens menu (see the product page).
- An X right at power-on (sensor not found)? → Check SDA = P20 and SCL = P19 are not swapped, that the external power is on, and with crocodile clips that no clip touches the neighbouring pad.
- All zeros in the simulator? → Normal. The MakeCode simulator has no real I2C, every read is 0; download to the micro:bit to see real values.
- No sound on a V1? → The V1 has no speaker; connect a buzzer or headphones between P0 and GND.
Example 2: Beep when the chosen colour is seen
What this example does: The LEDs show the colour to look for (R red, Y yellow, G green, B blue); when the picture centre shows it → heart + beep. A / B select the next / previous colour. Teaches how to compare hues on a circle.
What you need
- Everything from example 1 plus a yellow brick
- On a V1 also a buzzer or headphones on P0
Wiring: Same as example 1.
Download: ex02_color_alarm.ts (right-click, save) → MakeCode New Project → gear → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript (top) → select all, delete, paste the file → Download and drag the .hex onto the MICROBIT drive.
Code
// Vision sensor ESP32CAM (school edition) × micro:bit example 2: beep when the chosen colour is seen
// What it does: the LEDs show the colour to look for (R red, Y yellow, G green, B blue); when the picture centre shows it → heart + beep. A / B select the next / previous colour.
// Wiring: camera SDA → P20, SCL → P19, VCC → external 5 V, GND → GND (common ground). On a V1 connect a buzzer or headphones to P0 for sound (V2 has a speaker).
// Setup: camera with 'Setting 1: COLOR' done; red, yellow, green and blue bricks.
// You see: the LEDs show R; a red brick in front → heart + beep; a green brick → nothing; press A → Y, now only the yellow brick triggers it.

const NAMES = ["R", "Y", "G", "B"]
const HUES = [0, 17, 33, 67]                              // hues of red, yellow, green, blue (0..100)
const TOL = 8                                             // within 8 counts as the same colour
let sel = 0

// hue is a circle: 0 and 100 are both red, so a difference over 50 wraps the other way
function sameHue(h: number, target: number): boolean {
    let d = Math.abs(h - target)
    if (d > 50) {
        d = 100 - d
    }
    return d <= TOL
}

input.onButtonPressed(Button.A, function () {
    sel = (sel + 1) % 4
})
input.onButtonPressed(Button.B, function () {
    sel = (sel + 3) % 4
})

basic.forever(function () {
    let h = mbc.camColor(MbcCamColor.Hue)                 // −1 = black / white / grey
    if (!mbc.camIsGrey() && sameHue(h, HUES[sel])) {
        basic.showIcon(IconNames.Heart, 0)
        music.playTone(Note.E, 150)
    } else {
        basic.showString(NAMES[sel])                      // a single letter shows without scrolling
    }
    basic.pause(100)
})
Step by step
NAMES/HUES: letters and hues of the four colours (red 0, yellow 17, green 33, blue 67);sel= which one is selected.sameHue(h, target):d = |h − target|; if over 50 thend = 100 − d(0 and 100 are both red, so go round the other way); within 8 counts as the same colour.forever:h = hue; not grey andsameHue→ heart +Note.E; otherwisebasic.showString(NAMES[sel])(a single letter does not scroll).- A:
sel = (sel + 1) % 4; B:(sel + 3) % 4, i.e. one step back.
What you should see
- Screen shows R: a red brick in front → heart + beep; a green one → nothing.
- Press A → Y: now only the yellow brick triggers it.
- Press A until B (blue): a blue brick triggers, a cyan one may not (too far off).
FAQ
- Yellow is not recognised? → Warm or cool lighting shifts the hue. Press A to read the real number and put it into
HUESinstead of 17. - It beeps all the time? → The background happens to be that colour (a wooden desk is close to yellow). Change
TOLfrom 8 to 5.
Example 3: Camera pan servo tracks the blob
What this example does: The camera sits on a servo: blob on the left of the picture → the servo turns left until the blob is back in the middle; no blob → puzzled face, servo holds. Press A to centre.
What you need
- Everything from example 1
- one 9 g servo (SG90) with the camera fixed to its arm
- a 4.8–6 V battery pack and jumper wires
- the camera with "Setting 2: TRACK" done (a tracking box on screen)
Wiring: Camera as in example 1 (external 5 V). Servo orange (signal) → P1, red → external 4.8–6 V battery +, brown → battery −, and run a second wire from battery − to micro:bit GND (common ground). The camera is fixed to the servo arm.
Download: ex03_pan_servo.ts (right-click, save) → MakeCode New Project → gear → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript (top) → select all, delete, paste the file → Download and drag the .hex onto the MICROBIT drive.
Code
// Vision sensor ESP32CAM (school edition) × micro:bit example 3: camera pan servo tracks the blob
// What it does: the camera sits on a servo: blob on the left of the picture → servo turns left until the blob is back in the middle; no blob → puzzled face, servo holds. Press A to centre.
// Wiring: camera SDA → P20, SCL → P19, VCC → external 5 V, GND → GND. Servo orange (signal) → P1, red → external 4.8–6 V battery +, brown → battery − joined to micro:bit GND.
// Setup: camera with 'Setting 2: TRACK' done (the tracking box follows the blob); a 9 g servo (SG90) with the camera fixed to its arm.
// You see: move the blob slowly left and the servo follows so the blob stays centred; take the blob away → puzzled face.

const CENTRE = 50                                         // blob X 0..100, 50 = picture centre
const DEAD = 8                                            // hold still within 8 of centre
let angle = 90

basic.forever(function () {
    if (mbc.camFound()) {                                 // a blob of the target colour is found
        let err = mbc.camBlob(MbcCamBlob.X) - CENTRE      // positive = blob on the right
        if (Math.abs(err) > DEAD) {
            angle = Math.constrain(angle - err / 10, 0, 180)   // blob on the right → smaller angle = turn right (swap − for + if mounted mirrored)
            basic.showArrow(err > 0 ? ArrowNames.East : ArrowNames.West, 0)
        } else {
            basic.showIcon(IconNames.Target, 0)           // locked on
        }
        pins.servoWritePin(AnalogPin.P1, Math.round(angle))
    } else {
        basic.showIcon(IconNames.Confused, 0)
    }
    basic.pause(40)
})

input.onButtonPressed(Button.A, function () {
    angle = 90
    pins.servoWritePin(AnalogPin.P1, 90)
})
Step by step
CENTRE = 50(middle of blob X),DEAD = 8(hold still within 8 of centre),angle = 90.forever:mbc.camFound()→err = blob X − 50, positive = blob on the right.|err| > 8:angle = angle − err / 10(blob on the right → smaller angle = turn right; swap − for + if mounted mirrored), clamped to 0..180 withMath.constrain, arrow shows the direction; centred → target icon.pins.servoWritePin(AnalogPin.P1, Math.round(angle)).- No blob → puzzled face. A: back to 90°.
What you should see
- Blob in the middle: target icon, servo still.
- Move the blob slowly left: left arrow, the servo follows and stops once the blob is centred.
- Take the blob away: puzzled face.
FAQ
- The servo runs away (wrong direction)? → Change
angle − err / 10toangle + err / 10. - It oscillates? → Change
/ 10to/ 20(track slower), orDEADto 12. - The tracking box jumps to other objects? → TOL_HUE is too wide or MIN AREA too small in the camera settings; adjust them on the camera.
Example 4: Car chases the blob
What this example does: Blob on the right of the picture → turn right; blob small (far) → forward; big (near) → back; not seen → stop. A = start, B = stop. Uses the area as a distance.
What you need
- A two-wheel car: two continuous-rotation servos (e.g. FS90R) as wheels plus a caster
- the camera fixed at the front facing forward (external 5 V)
- a 4.8–6 V battery pack
- a ball or brick of the target colour; the camera with "Setting 2: TRACK" done
Wiring: Camera as in example 1 (external 5 V), mounted at the front facing forward. Left continuous-rotation servo signal → P1, right → P2; both servo red wires to the 4.8–6 V battery pack +, brown to battery −, and battery − also to micro:bit GND.
Download: ex04_follow_blob.ts (right-click, save) → MakeCode New Project → gear → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript (top) → select all, delete, paste the file → Download and drag the .hex onto the MICROBIT drive.
Code
// Vision sensor ESP32CAM (school edition) × micro:bit example 4: car chases the blob
// What it does: blob on the right of the picture → turn right; blob small (far) → forward; big (near) → back; not seen → stop. A = start, B = stop.
// Wiring: camera SDA → P20, SCL → P19, VCC → external 5 V, GND → GND. Left continuous-rotation servo signal → P1, right → P2; servos on a 4.8–6 V battery pack whose − is joined to micro:bit GND.
// Setup: a two-wheel car with the camera facing forward; camera with 'Setting 2: TRACK' done; a ball or brick of the target colour.
// You see: after A put the ball in front: move it back and the car chases, bring it close and the car reverses, move it sideways and the car turns; take it away → stop, puzzled face.

const FAR_AREA = 800                                      // area below this = too far → forward (tune for your ball)
const NEAR_AREA = 2500                                    // area above this = too close → back
let running = false

// left servo P1, right servo P2 (continuous rotation); left / right = −100..100, positive = forward
function drive(left: number, right: number): void {
    left = Math.constrain(left, -100, 100)
    right = Math.constrain(right, -100, 100)
    pins.servoWritePin(AnalogPin.P1, Math.round(90 + left * 0.9))    // 90 = stop, 180 = full forward, 0 = full reverse
    pins.servoWritePin(AnalogPin.P2, Math.round(90 - right * 0.9))   // the right servo is mounted mirrored, so subtract
}

input.onButtonPressed(Button.A, function () {
    running = true
    basic.showIcon(IconNames.Happy, 0)
})
input.onButtonPressed(Button.B, function () {
    running = false
    drive(0, 0)
    basic.showIcon(IconNames.No, 0)
})

basic.forever(function () {
    if (!running) {
        basic.pause(100)
        return
    }
    if (!mbc.camFound()) {
        drive(0, 0)
        basic.showIcon(IconNames.Confused, 0)
    } else {
        let x = mbc.camBlob(MbcCamBlob.X)                 // 0 (left) .. 100 (right)
        let area = mbc.camBlob(MbcCamBlob.Area)           // width × height, 0..7500: bigger = nearer
        let turn = Math.constrain((x - 50), -40, 40)      // blob on the right → positive → left faster = turn right
        let speed = 0
        if (area < FAR_AREA) {
            speed = 50                                    // too far: forward
        } else if (area > NEAR_AREA) {
            speed = -40                                   // too close: back
        }
        drive(speed + turn, speed - turn)
        if (turn > 10) {
            basic.showArrow(ArrowNames.East, 0)
        } else if (turn < -10) {
            basic.showArrow(ArrowNames.West, 0)
        } else if (speed > 0) {
            basic.showArrow(ArrowNames.North, 0)
        } else if (speed < 0) {
            basic.showArrow(ArrowNames.South, 0)
        } else {
            basic.showIcon(IconNames.Target, 0)           // distance just right
        }
    }
    basic.pause(40)
})
Step by step
FAR_AREA = 800,NEAR_AREA = 2500: an area (width × height) below 800 is too far, above 2500 too close; tune for your ball.function drive(left, right): left wheel P1, right wheel P2. A starts, B stops.forever:!mbc.camFound()→ stop, puzzled face.x = blob X,area = blob area;turn = x − 50(limited to ±40): blob on the right → positive → left wheel faster = turn right.speed: too far 50, too close −40, just right 0;drive(speed + turn, speed − turn). An arrow or the target icon shows what it is doing.
What you should see
- Press A, ball 30 cm ahead: the car drives forward; ball at 10 cm: reverses; somewhere between: stops, target icon.
- Ball to the right: turns right after it.
- Ball removed: stop, puzzled face.
FAQ
- It neither advances nor reverses? → The area sits between 800 and 2500. Read the A (area) value on the camera screen and adjust the two limits.
- It turns the wrong way? → Change
drive(speed + turn, speed − turn)todrive(speed − turn, speed + turn). - The picture blurs and the tracking box vanishes when moving? → Change the speed 50 to 35, or lower MIN AREA on the camera.
Example 5: Motion alarm + tracking turret (all together)
What this example does: Movement in the picture (motion > 30) → alarm and the count goes up (at most once per 2 s); when a blob is found the servo turns toward it (as in example 3); blob found / lost shows a tick / X through events. A resets, B toggles the alarm.
What you need
- The turret from example 3 (camera on the servo)
- On a V1 also a buzzer or headphones on P0
Wiring: Same as example 3.
Download: ex05_motion_guard.ts (right-click, save) → MakeCode New Project → gear → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript (top) → select all, delete, paste the file → Download and drag the .hex onto the MICROBIT drive.
Code
// Vision sensor ESP32CAM (school edition) × micro:bit example 5: motion alarm + tracking turret (all together)
// What it does: movement in the picture (motion > 30) → alarm and the count goes up (at most once per 2 s); when a blob is found the servo turns toward it (as in example 3); blob found / lost shows a tick / X. A resets, B toggles the alarm.
// Wiring: camera SDA → P20, SCL → P19, VCC → external 5 V, GND → GND. Servo signal → P1, servo on its own 4.8–6 V supply, common ground. On a V1 put a buzzer on P0 for sound.
// Setup: camera with 'Setting 2: TRACK' done; camera fixed to the servo arm.
// You see: someone walks past → beep, number +1; bring a target-colour brick in → tick and the servo follows it; press B → M (muted).

const MOTION_LEVEL = 30                                   // motion 0..100, above this counts as movement
let armed = true
let alarms = 0
let lastAlarm = -5000
let angle = 90

mbc.onCamBlob(MbcCamEvent.Found, function () {            // blob appears
    basic.showIcon(IconNames.Yes, 0)
})
mbc.onCamBlob(MbcCamEvent.Lost, function () {             // blob disappears
    basic.showIcon(IconNames.No, 0)
})

input.onButtonPressed(Button.A, function () {
    alarms = 0
    basic.showNumber(0)
})
input.onButtonPressed(Button.B, function () {
    armed = !armed
    basic.showString(armed ? "S" : "M")                   // S = alarm on, M = muted
})

basic.forever(function () {
    let m = mbc.camMotion()                               // whole-picture motion 0..100
    if (armed && m > MOTION_LEVEL && control.millis() - lastAlarm > 2000) {
        alarms += 1
        lastAlarm = control.millis()
        music.playTone(Note.A, 300)                       // the servo twitches during the beep; normal (shared PWM period)
        basic.showNumber(alarms)
    }
    if (mbc.camFound()) {                                 // blob present: the turret follows it
        let err = mbc.camBlob(MbcCamBlob.X) - 50
        if (Math.abs(err) > 8) {
            angle = Math.constrain(angle - err / 10, 0, 180)
        }
        pins.servoWritePin(AnalogPin.P1, Math.round(angle))
    }
    basic.pause(50)
})
Step by step
MOTION_LEVEL = 30,armed = true,alarms,lastAlarm.mbc.onCamBlob(Found, ...)→ tick;Lost→ X.- A:
alarms = 0; B: fliparmed, show S / M. forever:m = mbc.camMotion(); ifarmedandm > 30and more than 2 s since the last alarm →alarms + 1,Note.Afor 0.3 s, show the count.mbc.camFound()→ computeerr, updateangleand move the servo as in example 3.
What you should see
- Someone walks past: beep, shows 1; again: 2.
- Bring a target-colour brick in: tick, the servo follows it; remove it: X.
- Press B: M, no more beeps but tracking continues.
FAQ
- The servo twitches during the beep? → Normal: the micro:bit PWM channels share one period, so the buzzer disturbs the servo pulse. Replace
music.playTonewith LED flashing if it bothers you. - The servo moving triggers the alarm? → The camera turns with the servo, so the picture moves. Ignore motion while tracking: add
!mbc.camFound() &&in front ofarmed && .... - Alarms all the time? → Change
MOTION_LEVELto 50, or the lighting flickers (fluorescent tubes).
Example 6: All 12 colour spots at a glance (WRO edition HUE12)
What this example does: WRO edition only: the top 3 LED rows = spots S1..S12 (4 per row), colour bright, white dim, black or off dark; the dot on row 5 = the selected spot. Press A to select the next spot, B to show its colour code and vividness.
What you need
- micro:bit V1 or V2 + USB cable
- Vision Sensor ESP32CAM WRO edition (HUE12) + external 5 V
- a WRO mat or a few colour, white and black bricks
- the 12 spot positions set on the camera first
Wiring: Same as example 1.
Download: ex06_wro_spots.ts (right-click, save) → MakeCode New Project → gear → Extensions → paste https://github.com/contactmbcrobot/pxt-mbc-sensors → switch to JavaScript (top) → select all, delete, paste the file → Download and drag the .hex onto the MICROBIT drive.
Code
// Vision sensor ESP32CAM (WRO edition, HUE12) × micro:bit example 6: all 12 colour spots at a glance
// What it does: the top 3 LED rows = spots S1..S12 (4 per row): colour → bright, white → dim, black or off → dark. The dot on row 5 = the selected spot. Press A to select the next spot, B to show its colour code and vividness.
// Wiring: camera SDA (IO3) → P20, SCL (IO1) → P19, VCC → external 5 V, GND → GND (common ground).
// Setup: on the WRO edition camera set the 12 spot positions first (see the product page).
// You see: spots over coloured bricks bright, over white dim, over black dark; press B for the colour code: 0..239 colour (red ≈ 0, yellow ≈ 40, green ≈ 80, blue ≈ 160), 240..245 white, 246..250 black, 255 = spot off.

let sel = 1                                               // selected spot 1..12
let busy = false

if (mbc.waitReady(mbc.ADDR_CAM, 5000)) {
    basic.showIcon(IconNames.Yes)
} else {
    basic.showIcon(IconNames.No)
}

basic.forever(function () {
    if (busy) {
        basic.pause(100)
        return
    }
    basic.clearScreen()
    for (let n = 1; n <= 12; n++) {
        let x = (n - 1) % 4                               // 4 per row
        let y = Math.idiv(n - 1, 4)                       // rows 0..2
        if (mbc.camSpotIs(n, MbcCamSpotKind.Colour)) {    // code 0..239
            led.plotBrightness(x, y, 255)
        } else if (mbc.camSpotIs(n, MbcCamSpotKind.White)) {   // 240..245
            led.plotBrightness(x, y, 40)
        }
    }
    led.plot((sel - 1) % 4, 4)                            // row 5: column of the selected spot
    basic.pause(100)
})

input.onButtonPressed(Button.A, function () {
    sel = sel % 12 + 1                                    // 1 → 2 → … → 12 → 1
    busy = true
    basic.showString("S" + sel)
    busy = false
})
input.onButtonPressed(Button.B, function () {
    busy = true
    basic.showNumber(mbc.camSpotColor(sel))               // colour code 0..255
    basic.showString("V")
    basic.showNumber(mbc.camSpotVivid(sel))               // vividness 0..255
    busy = false
})
Step by step
sel = 1: the selected spot.waitReadyticks.forever: clear,for n = 1..12:x = (n − 1) % 4,y = (n − 1) ÷ 4(integer divisionMath.idiv) → rows 0..2, 4 per row.mbc.camSpotIs(n, Colour)(code 0..239) →led.plotBrightness(x, y, 255)full;White(240..245) → 40 dim; black / off → not drawn.led.plot((sel − 1) % 4, 4): row 5 marks the column of the selected spot.- A:
sel = sel % 12 + 1cycles 1..12 and shows S plus the number; B: showscamSpotColor(sel), V,camSpotVivid(sel).
What you should see
- A spot over a coloured brick: full brightness; white: dim; black: dark; spot off: dark.
- Press A: S2, S3 …; the row-5 dot moves along.
- Press B: e.g. 40 (yellow), V, 180.
FAQ
- Everything dark? → None of the 12 spots is enabled (code 255); set the spot positions on the camera.
- The codes differ from the SPIKE page? → I2C gives a 0..255 colour code (colour 0..239); the SPIKE modes use another scaling; see the Reference for the mapping.
Next steps
- Every block, value and hardware note: Vision Sensor ESP32CAM × micro:bit
- What each value id means: Reference
- Extension source and issues: https://github.com/contactmbcrobot/pxt-mbc-sensors