
Vision Sensor (School Edition) × micro:bit (MakeCode extension)
Back to Vision Sensor (School Edition)
The universal I2C edition of the Vision Sensor (School Edition) works with BBC micro:bit V1 / V2 through the MakeCode extension pxt-mbc-sensors v2 (which speaks MBC I2C protocol v2). Installation and hardware notes (3.3 V, power): micro:bit overview.
SPIKEEV3Arduino I2CmBlockMATRIXmicro:bit
Important
Extension v2 is not yet verified on hardware; block names follow the published release: https://github.com/contactmbcrobot/pxt-mbc-sensors
Wiring
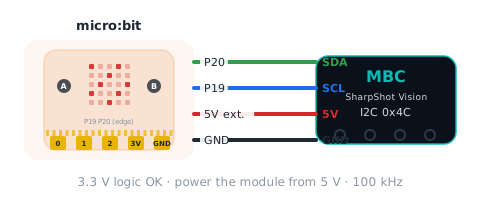
| Sensor | micro:bit |
|---|---|
| SDA(RX) | P20 |
| SCL(TX) | P19 |
| VCC | must use external 5 V (share GND with the micro:bit) |
| GND | GND |
Reporter blocks
| Block | Returns | Id | Meaning |
|---|---|---|---|
| camera colour [hue] | -1~100 | 01 |
hue of sample point S1, 0 |
| camera colour [saturation] | 0~100 | 02 |
saturation of sample point S1, 0~100 |
| camera colour [brightness] | 0~100 | 03 |
brightness (HSV value) of sample point S1, 0~100 |
| camera motion | 0~100 | 04 |
whole-frame motion 0~100 (more change = larger) |
| camera blob [X] | 0~100 | 05 |
blob centre X 0~100, left = 0; 0 when not found |
| camera blob [Y] | 0~75 | 06 |
blob centre Y 0~75, bottom = 0, top = 75; 0 when not found |
| camera blob [width] | 0~100 | 07 |
blob width W 0~100; 0 = not found |
| camera blob [height] | 0~75 | 08 |
blob height H 0~75; 0 when not found |
| camera blob [area] | 0~7500 | 09 |
W×H (0~7500); 0 when not found |
| camera blob is found | 0~1 | 0A |
1 = a blob of the target colour is in view (W > 0), 0 = none |
More blocks (yes / no, events)
| Block | Related value |
|---|---|
| camera colour is black / white / grey | 01 |
| on camera blob [found] | 0A |
Status
| bit | Name | Meaning |
|---|---|---|
| b0 | ready (ready) |
always 1 (values freeze while the camera menu is open) |
| b1 | blob found (found) |
same as value 0A |
JavaScript
if (!(mbc.waitReady(0x4C, 3000))) {
    basic.showIcon(IconNames.No)   // nothing answers: check wiring and power
}
basic.forever(function () {
    basic.showNumber(mbc.camColor(MbcCamColor.Hue))   // hue
    basic.pause(100)
})
Sources and assumptions
Generated by _build/gen-reference.mjs from _build/protocol/cam_school.json (single source of truth, transcribed from the 2026-10-21 protocol decisions).
- hw0 = 1(共識 #6:神攝手 1 = 學校版);model 字串 CAMSCH 照任務指定(韌體原本沒有型號欄位)。
- D4:I2C 0x4C 用 SDA = IO3、SCL = IO1(沿 PS4 Wire.setPins 慣例),與 EV3/SPIKE 串口模式二選一編譯;ESP32 從機不能時脈延展,onReceive 預載 32 B;頁面標「硬體已確認,上機待測」。mBlock 用同一組腳 Serial.begin(38400, SERIAL_8N1, 3, 1)。
- EV3 六個模式全部鎖住照盤點(模式 3/5 的 −1 已在 #65 修成符號延伸);EV3 定案最後的 golden 備註把 cam_school 列進「模式 5 改 ID」是筆誤(定案表本身寫「—」;模式 5 仍是 [色相, 飽和]),所以 ev3IdMode = null。
- SPIKE 模式 9 鎖住,只有 byte 8
9(v[4])從 0 改成面積 W×H;模式 6 改 [X, Y, 面積];模式 8 = [0x4C | 1<<8, 2, 韌體版, 更新序號];模式 14 維持 0。 - SPIKE 模式 0 的「面積」是 map(像素面積 0
5000 → 0100),跟值表 09 的 W×H 不同,鎖住不改(照盤點)。 - mVision:N = 10(idx 0~9),色相 −1 送 255;每 20 ms 一包(B-6);不做 0x22(hosts.matrix = false)。
- 0A 有找到色塊 = W > 0(盤點:W 0 = 沒找到);F3 b1 同這個值。
- 值 05~08 的「沒找到 = 0」照盤點 §0;色塊 Y 下 = 0、上 = 75 照盤點(map(bestY,120,0,0,75))。
- 沒有寫入命令(韌體無法從程式改目標顏色/補光燈)。
- The extension reads
Int16LEand pauses 2 ms after writing the id (D5); with no sensor answering, reporters return 0 and yes / no blocks return false.