
IMU Gyro Sensor × Arduino I2C (universal I2C edition)
The universal I2C edition of the IMU Gyro Sensor speaks MBC I2C protocol v2: write one id, read 2 bytes = one int16 little-endian value; consecutive ids can be read in one go. This page has the value table, commands and wiring for this product; the shared rules (F0~F5 version & status, F8 re-address, EF reboot) are on the universal I2C protocol page.
SPIKEEV3Arduino I2CmBlockMATRIXmicro:bit
Tip
New to coding? Start with the Arduino examples; every sketch is copy-and-upload. The six-host reading of every value is in the reference.
Basics
| Item | Detail |
|---|---|
| I2C address | 0x6A(change with F8) |
| F0 device ID | low byte 0x6A、high byte 1 |
| Model | IMU |
| Protocol F1 | 2 |
| Speed | 100 kHz (recommended) / 400 kHz; wait 2 ms after writing the id |
| Read | 主機寫 [編號] → 等 2 ms → 讀 2×k byte(k≤16)= 從該編號起連續 k 個 int16 小端;空號回 -32768 |
| Snapshot | updated every 10 ms; a multi-value read is atomic |
Wiring
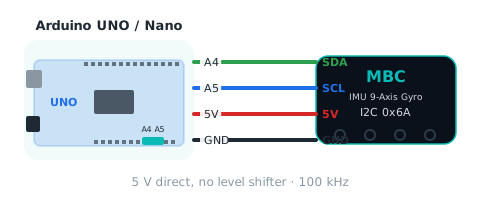
| Sensor | Arduino UNO / Nano | Arduino R4 | ESP32 |
|---|---|---|---|
| SDA | A4 | SDA | GPIO 21 |
| SCL | A5 | SCL | GPIO 22 |
| 5V | 5V | 5V | 5V |
| GND | GND | GND | GND |
Works directly with 5 V hosts, no level shifter; two products with the same address cannot share a bus (re-address one with F8 first).
Value table
Each id returns one int16; click an id for the six-host reading and figure.
| Id | Value | Range | Meaning |
|---|---|---|---|
01 |
gyro 3D heading headingGyro3D |
-32768~32767 ° | heading from the 3D quaternion, degrees, 0 at boot/zero, accumulates past 360 (wraps at ±32767, ~91 turns) |
02 |
fused heading headingFused |
-32768~32767 ° | 3D gyro heading slowly corrected by the magnetometer, degrees, relative to the zero point; may exceed 360 |
03 |
gyro 1D heading headingGyro1D |
-32768~32767 ° | heading integrated about the yaw axis only, degrees, 0 at boot/zero; may exceed 360 |
04 |
magnetic heading headingMag |
-32768~32767 ° | tilt-compensated magnetometer heading, degrees, relative to the zero point |
05 |
yaw rate yawRate |
-32768~32767 0.1 dps | angular rate about the yaw axis (getYawAxis()), 0.1 deg/s, same sign as the heading |
06 |
pitch angle pitch |
-90~+90 ° | elevation of the board's printed X axis above horizontal: +90 pointing up, −90 pointing down, 0 level (from the gravity vector) |
07 |
pitch rate pitchRate |
-32768~32767 0.1 dps | angular rate about the board's printed X axis, 0.1 °/s (right-hand rule, CCW seen from +X is positive); this is gyro X, not the derivative of 06 |
08 |
magnetometer trust magTrust |
0~255 | how much the fusion trusts the magnetometer, 0 |
09 |
magnetic disturbance magDisturb |
0~255 0.01° | magnetic disturbance level 0~255 (degrees × 100, capped at 255) |
0A |
face up upFace |
0~5 | which axis points up: 0 +X, 1 +Y, 2 +Z, 3 −X, 4 −Y, 5 −Z (physical axes) |
10~12 |
gyro axis 1~3 gyro |
-32768~32767 0.1 dps | 10 X, 11 Y, 12 Z angular rate, 0.1 deg/s (physical axes, sign-corrected) |
13~15 |
accel axis 1~3 accel |
-32768~32767 mg | 13 X, 14 Y, 15 Z acceleration, mg (1000 = 1 g) |
16~18 |
mag axis 1~3 mag |
-32768~32767 mG | 16 X, 17 Y, 18 Z magnetic field, mG (milligauss) |
0B |
command status cmdStatus |
0~0xEF03 | (last command code << 8) | state; state 0 done, 1 busy, 2 failed, 3 rejected (same codes as the SPIKE command reply (mode 8 v3)); reported for E1~EB; undefined codes after EB: ignored on I2C, 0B unchanged (SPIKE replies 3 rejected) |
Write commands
| Id | Command | Parameters | Meaning |
|---|---|---|---|
E0 |
zero heading zeroHeading |
— | zero all four headings (zeroHeadings()); EV3 also accepts the stock gyro-reset WRITE 0x11 |
E1 |
start accelerometer calibration accelCalStart |
— | start accelerometer calibration (= v1 0x20=0x01); F3 b4 = 1 meanwhile; ignored during magnetometer calibration (0B state 3 rejected)(F3 bit4 = 1 while running) |
E2 |
end accelerometer calibration accelCalEnd |
— | finish accelerometer calibration and save to EEPROM (= v1 0x20=0x02); on success the mount axis is re-captured and headings are zeroed once the sensor is level and still (not immediately); rejected if not calibrating (0B state 3); failed check → 0B state 2 |
E3 |
start magnetometer calibration magCalStart |
— | start magnetometer calibration (= v1 0x20=0x03); F3 b5 = 1 meanwhile; ignored if the magnetometer has failed (0B state 3)(F3 bit5 = 1 while running) |
E4 |
end magnetometer calibration magCalEnd |
— | finish magnetometer calibration and save to EEPROM (= v1 0x20=0x04); headings zeroed right away on success; rejected if not calibrating (0B state 3); failed check → 0B state 2 |
E5 |
set heading setHeading |
angle int16 ° | [angle int16 little-endian]: all four headings set to this angle (RAM); rejected while calibrating (0B state 3) |
E6 |
north as zero zeroNorth |
— | gyro heading set to the current magnetic bearing 0~359, then only whole turns are removed (absolute bearing); fusion re-init within ~3 s, timeout = failed; rejected while calibrating (0B state 3) |
E7 |
re-estimate gyro bias gyroBiasReset |
— | re-estimates the gyro bias over ~1.5 s of stillness (3 still windows); moved and not done within 4 s = failed; rejected while calibrating (0B state 3) |
E8 |
re-capture mount axis recaptureAxis |
— | re-detects the mounting orientation (headings zeroed after capture); RAM; rejected while calibrating (0B state 3) |
E9 |
cancel calibration cancelCalib |
— | cancels the running accelerometer / magnetometer calibration without saving (old values restored) |
EA |
heading correction headingCorrection |
0.1°/turn 0, 3500~3700 | [uint16 little-endian] actual degrees per turn × 10 (0.1°/turn), 3500~3700; 0 = back to 360.0. Saved to EEPROM 0x60 (written after 3 s, skipped if unchanged), headings zeroed afterwards; missing or out of range → 0B state 2 (SPIKE also 2) |
EB |
calibration factory reset calibFactoryReset |
magic 0xA5 | [A5]: accelerometer, magnetometer calibration and heading correction back to factory values, saved immediately; wrong magic → 0B state 2; rejected while calibrating (3) |
Status flags F3
| bit | Name | Meaning |
|---|---|---|
| b0 | ready (ready) |
always 1 |
| b1 | stationary (still) |
1 = sensor is stationary |
| b2 | mount axis captured (axisCaptured) |
1 = mounting orientation determined (headings zeroed once after first capture) |
| b3 | mount too tilted (mountTilted) |
1 = mounted too far from level |
| b4 | accel calibrating (accelCalibrating) |
1 between E1 and E2 |
| b5 | mag calibrating (magCalibrating) |
1 between E3 and E4 |
| b6 | fusion initialised (fusionInit) |
1 = fused heading is valid |
| b7 | mag auto-cal converged (magAutoCalDone) |
1 = magnetometer auto-calibration offsets have converged |
Shared registers
| Id | Name | Meaning |
|---|---|---|
F0 |
device ID | low byte = factory I2C address (unchanged after re-addressing), high byte = hw[0] (channels / sensors / variant) |
F1 |
protocol version | 2 for this release (same number reported in SPIKE mode 8 v[1]) |
F2 |
firmware version | major×100 + minor (e.g. 102 = 1.2) |
F3 |
status flags | b0 = ready; other bits per product (see flags) |
F4 |
update counter | +1 every 10 ms snapshot, wraps 0~255 (2.56 s per cycle, not usable for reboot detection; frozen = module busy) |
F5 |
uptime seconds | seconds since boot, saturates at 32767 (~9 h); a drop means the module rebooted |
F8 |
change I2C address | [F8][new 0x08 |
EF |
reboot | [EF][0xA5]; mBlock sends ACK first, then reboots |
Single-file helper functions
No library to install. Paste it in two parts: part ① (2 lines) at the top of the sketch, part ② at the bottom. #include <Wire.h> and MBC_NONE must appear before setup() uses them; pasting everything at the bottom will not compile.
① At the top of your sketch (before setup())
#include <Wire.h>

const int16_t MBC_NONE = -32768;   // no answer / undefined id
② At the bottom of your sketch (after loop())
// read k consecutive values (k ≤ 16) starting at id, int16 little-endian
bool mbcReadMany(uint8_t addr, uint8_t id, uint8_t k, int16_t *out) {
  Wire.beginTransmission(addr);
  Wire.write(id);
  if (Wire.endTransmission() != 0) return false;
  delay(2);                                        // always wait 2 ms (ESP32 products cannot clock-stretch)
  if (Wire.requestFrom(addr, (uint8_t)(k * 2)) != (uint8_t)(k * 2)) return false;
  for (uint8_t i = 0; i < k; i++) {
    uint8_t lo = Wire.read(), hi = Wire.read();
    out[i] = (int16_t)(lo | (hi << 8));
  }
  return true;
}

// read one value; MBC_NONE when nothing answers
int16_t mbcRead(uint8_t addr, uint8_t id) {
  int16_t v;
  return mbcReadMany(addr, id, 1, &v) ? v : MBC_NONE;
}

// write a command (0~3 parameters)
// with 2 parameters whose first is 0, write (uint8_t)0, e.g. mbcWrite(ADDR, 0xF8, (uint8_t)0x00, 0xFF); otherwise it clashes with the array form below and will not compile
void mbcWrite(uint8_t addr, uint8_t id, const uint8_t *args, uint8_t n) {
  Wire.beginTransmission(addr);
  Wire.write(id);
  for (uint8_t i = 0; i < n; i++) Wire.write(args[i]);
  Wire.endTransmission();
}
void mbcWrite(uint8_t addr, uint8_t id) { mbcWrite(addr, id, nullptr, 0); }
void mbcWrite(uint8_t addr, uint8_t id, uint8_t a) { mbcWrite(addr, id, &a, 1); }
void mbcWrite(uint8_t addr, uint8_t id, uint8_t a, uint8_t b) { uint8_t p[2] = {a, b}; mbcWrite(addr, id, p, 2); }
void mbcWrite(uint8_t addr, uint8_t id, uint8_t a, uint8_t b, uint8_t c) { uint8_t p[3] = {a, b, c}; mbcWrite(addr, id, p, 3); }

// wait until ready (F3 bit0 = 1), at most ms milliseconds
bool mbcWaitReady(uint8_t addr, unsigned long ms) {
  unsigned long t0 = millis();
  while (millis() - t0 < ms) {
    int16_t st = mbcRead(addr, 0xF3);
    if (st != MBC_NONE && (st & 1)) return true;
    delay(20);
  }
  return false;
}
Example: print the whole value table
// helper part ①
#include <Wire.h>

const int16_t MBC_NONE = -32768;   // no answer / undefined id

const uint8_t ADDR = 0x6A;

void setup() {
  Serial.begin(115200);
  Wire.begin();
#if defined(WIRE_HAS_TIMEOUT)
  Wire.setWireTimeout(25000, true);   // AVR: never hang when the module is silent
#endif
  if (!mbcWaitReady(ADDR, 2000)) Serial.println("module not found: check wiring and address");
  Serial.print("ID 0x"); Serial.println(mbcRead(ADDR, 0xF0), HEX);   // low byte address, high byte hw[0]
  Serial.print("FW ");    Serial.println(mbcRead(ADDR, 0xF2));
}

void loop() {
  Serial.print("headingGyro3D: "); Serial.println(mbcRead(ADDR, 0x01));   // gyro 3D heading
  Serial.print("headingFused: "); Serial.println(mbcRead(ADDR, 0x02));   // fused heading
  Serial.print("headingGyro1D: "); Serial.println(mbcRead(ADDR, 0x03));   // gyro 1D heading
  Serial.print("headingMag: "); Serial.println(mbcRead(ADDR, 0x04));   // magnetic heading
  Serial.print("yawRate: "); Serial.println(mbcRead(ADDR, 0x05));   // yaw rate
  Serial.print("pitch: "); Serial.println(mbcRead(ADDR, 0x06));   // pitch angle
  Serial.print("pitchRate: "); Serial.println(mbcRead(ADDR, 0x07));   // pitch rate
  Serial.print("magTrust: "); Serial.println(mbcRead(ADDR, 0x08));   // magnetometer trust
  Serial.print("magDisturb: "); Serial.println(mbcRead(ADDR, 0x09));   // magnetic disturbance
  Serial.print("upFace: "); Serial.println(mbcRead(ADDR, 0x0A));   // face up
  { int16_t a[3]; mbcReadMany(ADDR, 0x10, 3, a); Serial.print("gyro: "); for (uint8_t i = 0; i < 3; i++) { Serial.print(a[i]); Serial.print(' '); } Serial.println(); }
  { int16_t a[3]; mbcReadMany(ADDR, 0x13, 3, a); Serial.print("accel: "); for (uint8_t i = 0; i < 3; i++) { Serial.print(a[i]); Serial.print(' '); } Serial.println(); }
  { int16_t a[3]; mbcReadMany(ADDR, 0x16, 3, a); Serial.print("mag: "); for (uint8_t i = 0; i < 3; i++) { Serial.print(a[i]); Serial.print(' '); } Serial.println(); }
  Serial.print("cmdStatus: "); Serial.println(mbcRead(ADDR, 0x0B));   // command status
  Serial.println();
  delay(200);
}

// paste part ② of the helper functions below
Sources and assumptions
Generated by _build/gen-reference.mjs from _build/protocol/imu.json (single source of truth, transcribed from the 2026-10-21 protocol decisions).
- hw0 = 1(共識 #6);EV3 模式 4 = [0x6A | 1<<8, 韌體主×100+次, 0, 0](格式 B 再補 2 個 0),模式 5 改送俯仰角速度(取代 #65 放的 ID)。
- EV3 鎖住模式 0/1/3 照盤點程式碼:0 = 陀螺 3D、1 = 融合航向、3 = [陀螺 1D, 磁力航向](INO:213 註解寫反,以程式為準)。
- 0x22 照 R4 版(出貨版)鎖住:命令 4
9 = 三個航向 +32768 的「低 byte 在前、高 byte 在後」;盤點檔分析的是主韌體(高在前),主韌體 #67 改成跟 R4 版逐 byte 相同。命令 1012 = 0;0x01、0x0A、0x0F、F1~F4 都觸發航向歸零(刻意,不動)。 - B-13:E1~E4 加速度計/磁力計校準開始/結束補回(v1 的 0x20 = 01/02/03/04),I2C 定案 §3 只列 E0。busyFlag:E1 → b4、E3 → b5。
- 俯仰角範圍定案沒寫(韌體尚無現成值,#67 用 atan2 新算),range 先填「°」不給 min/max,韌體做好後再補。
- 磁力信任度 08 = round(trust×255),磁場干擾度 09 = round(disturbance×100) 上限 255,朝上的面 0A = 軸號 + 3×負向:公式照盤點 I2C v1 0x34~0x36。
- 角速度 10
12 = round(dps×SIGN×10)、加速度 1315 = mm/s²×1000/9806.65、磁力 1618 = raw×SIGN×4/15:公式照盤點 I2C v1 0x220x24;mBlock 一併有(I2C 定案 §4 共用值表)。 - 主對話 2026-10-22:06 俯仰角範圍 −90~+90、07 = gyro X(照字面),取自 F5 韌體實作。
- Pin table uses each board's common defaults (ESP32: change with
Wire.begin(sda, scl)).